Conveyor System Integration With Robotic Pick Stations
Handoff failures between conveyors and robots kill throughput even when each component works fine.
Advertisement
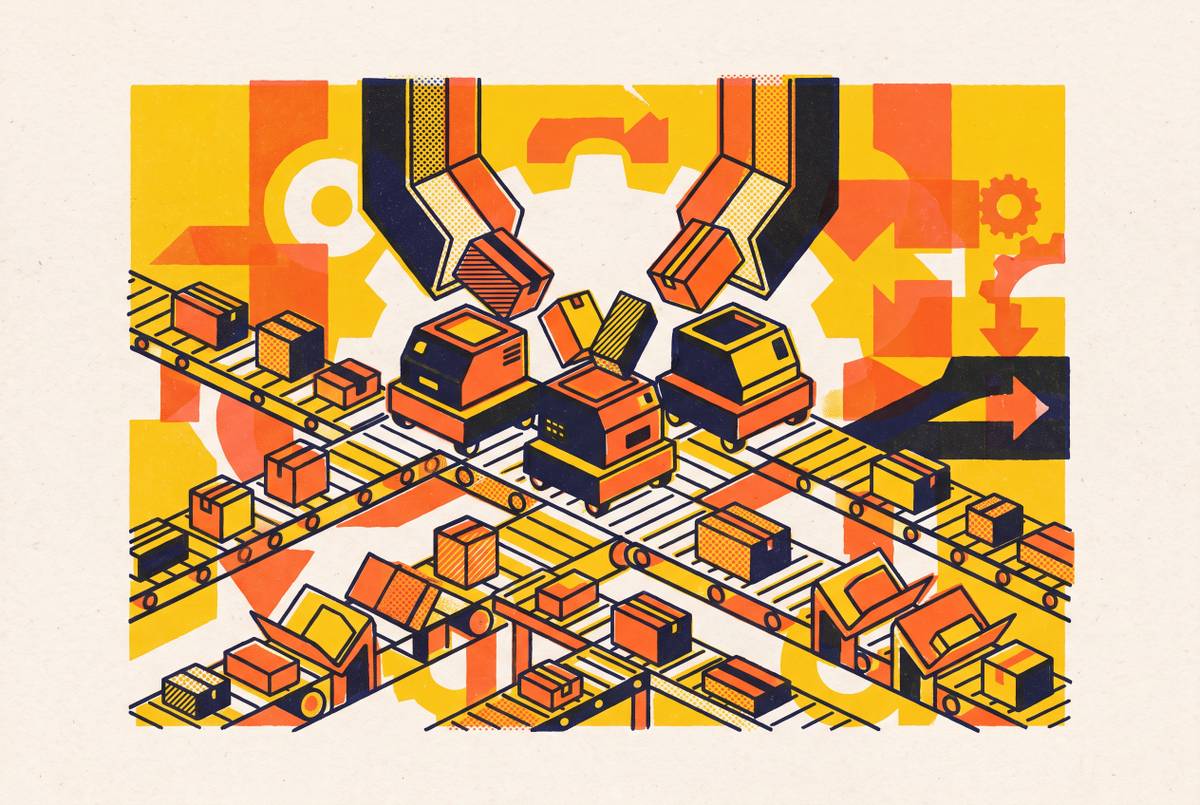
Conveyor-robot systems rarely fail because a conveyor is undersized or a robot arm lacks the reach or payload for its job. They fail at the handoffs between pieces of equipment that each work correctly on their own. A conveyor network acts as connecting tissue linking discrete automation cells: an automated guided vehicle drops product at an induction point, the conveyor carries it to a robotic pick station, and the finished order moves on toward packing. Each of those transitions is a place where signals can cross, timing can slip, or sequencing can break down, even when every component involved is working exactly as designed. Isolated automation tends to create inefficiency precisely at these interfaces, where product piles up and cycle time erodes while the individual machines keep running at spec. The rest of this article works through each junction layer in turn: physical buffering, the PLC handshake, vision-guided tracking, and the control-stack hierarchy that decides who's actually in charge of the robot at any given moment. If you understand how each layer hands off to the next, you can hold throughput across an entire line, not just at whichever station happens to run fastest.
The three-layer control stack
Three software layers typically divide responsibility for inventory, flow, and device control in a distribution center, and a common source of integration failure is confusion about which layer actually owns the conveyor-robot handshake. At the top sits the warehouse management system, the WMS, which handles inventory records, order management, and wave creation on a timescale measured in minutes or hours. At the bottom sits the warehouse control system, the WCS, working alongside PLCs to turn high-level decisions into real-time, deterministic commands for conveyors, motor controllers, and the AGV or AMR fleet on the floor. In between sits the warehouse execution system, the WES, which operates in real time: it sequences tasks, buffers workload, and routes work across both labor and automation at once. The WES decides which robot station gets which product next, and in what order.
The WMS was never built to synchronize with real-time robotics orchestration or to manage a mixed fleet of automation types working side by side. Operations that send WMS commands straight to a robot controller, skipping the WES layer, risk sequencing failures and mismatched APIs that appear only once volume climbs. A WCS layer, working with PLCs, translates those WES-level decisions into deterministic real-time commands for the hardware: motor controllers, AGVs, AMRs, and the discrete safety interlocks that sit below it. That translation layer between PLC or SCADA systems and robotics is what turns a set of separate automation islands, each running on its own clock, into infrastructure that can scale as new equipment gets added. Many facilities have spent heavily on robots, conveyors, and AS/RS hardware while still running a WES designed for a manual warehouse, or no real WES at all, to coordinate it. When physical investment outpaces orchestration software like this, it's the single most common reason integration projects stall after the equipment is already installed.
The PLC handshake between conveyor and robot controller
The handshake between a conveyor and a robot controller is a defined exchange of signals, and when that exchange is poorly specified, the result is deadlocks, missed picks, and fault cascades even when the conveyor and the robot each work fine on their own. The PLC manages this handshake directly: it confirms that product arrives correctly oriented and properly spaced before the robot attempts a pick. Spacing and orientation are conditions that have to be met before a pick cycle can start, not details to sort out after the fact.
At this interface, the conveyor's job is twofold: present the product in a consistent position and orientation, and hold it there until the robot controller signals that the pick is complete before releasing the next item. Common signal states passed between conveyor and robot controller include ready, busy, fault, cycle-complete, and part-arrived, and these states have to be wired to the PLC's logic with timeouts that resolve ambiguous conditions so the system does not wait indefinitely. You need to build safety interlocks, light curtains, area scanners, and e-stop circuits into that same PLC logic from the start, not add them on afterward. A robot that gets a pick signal while a safety interlock is tripped has to resolve that conflict in a predictable, repeatable way every time, because an interlock that behaves inconsistently under load functions as no interlock.
Accumulation and buffering: protecting robot cycle time from upstream variability
A handshake with clean signal logic still fails if the physical flow feeding it is erratic. Accumulation conveyor design matters as much as the PLC logic sitting on top of it. Without proper buffering, a system runs into two distinct failure modes: slugs, where large clusters of product arrive at once and overwhelm the robot's pick rate, and gaps, where the robot sits idle waiting for the next item. Both erode throughput, just in opposite directions.
Zero-pressure accumulation keeps fragile goods free of back-pressure or product-to-product contact while they queue at the pick station, and that matters most for packaging-sensitive SKUs, where even light contact damage turns into a quality failure downstream. You have to size the accumulation zone for the worst-case upstream surge, big enough that it doesn't overflow into the pick zone, but also big enough that it doesn't starve the robot. Undersizing is the more common mistake, and it's also the harder one to catch, because a buffer that looks adequate during commissioning with light test loads can still fail once real order volume hits the line. Upstream sortation, whether through diverters, pop-up wheels, or sliding shoe mechanisms, routes product to specific pick stations based on instructions from the WES, and that sortation decision has to be engineered together with the accumulation design so the rate of flow into each station actually matches that station's robot cycle time. High-speed sortation systems can move over 200 units per minute, and when the pick station downstream can't match that pace, the accumulation buffer is all that stands between that speed and a bottleneck. Get the buffer sizing wrong and the fastest part of the line becomes the reason the rest of it backs up.
Vision-guided conveyor tracking: how robots pick from a moving belt without stopping it
Vision-guided conveyor tracking means you don't have to stop the belt for every individual pick, and that one design choice is what separates continuous-flow systems running at real throughput from slower index-and-pick setups that stop and start for each item. A camera system tied into the robot controller detects part orientation, works out the product's position on the moving belt, and feeds that data to the robot's motion planner fast enough for the robot to adjust its pick trajectory for belt speed in real time.
senswork GmbH builds a SCARA-based system that pairs an intelligent vision system with real-time conveyor tracking: a single camera detects part orientation, determines tray position, and verifies that the part was placed correctly and completely, all from one sensor. That combination of tasks in one camera cuts system complexity while still hitting throughput up to 120 parts per minute. The data path from camera to robot controller has to stay synchronized with the robot's own motion clock, because any lag in image processing produces positional error at the moment of the pick; dedicated vision processors running deterministic software are the standard choice over general-purpose computing hardware in these setups.
Mixed-SKU and irregular product streams push this further. CMES Robotics' AI Vision system identifies and grips parcels of varying shapes, sizes, and packing orientations straight out of a gaylord, with no manual programming required for each new parcel type, and feeds those items onto a conveyor for whatever processing comes next. The same camera that guides the pick can also confirm correct placement, completeness, and orientation right after the pick happens, so the pick cell folds in what would otherwise be a separate inspection step.
Product-flow sequencing: how the WES coordinates the order in which products reach the robot
Getting product correctly spaced and correctly tracked at the pick station only pays off if the right product arrives at the right time, and that sequencing decision belongs to the WES. The WES has to balance several constraints at once: robot cycle time at each station, how much the accumulation buffers can hold, how fast packing downstream can absorb finished work, and outbound shipping deadlines. Optimizing for any single one of those in isolation degrades the rest of the system.
The WES makes the call on buffering strategy; it isn't fixed in the hardware. The WES decides when product gets released from an upstream buffer, at what rate, and in what order, specifically to avoid slugs at the pick station on one side and idle robot time on the other. In a goods-to-person setup, the WES coordinates mobile robots retrieving storage pods, assigns those pods to pick stations based on order priority and which stations are available, and re-queues a pod elsewhere if a station's buffer fills up, all in real time. RFID readers, barcode scanners, and vision systems sit along the conveyor path and feed location and identity data back to the WES continuously, so it can track where each item sits in the flow and adjust sequencing the moment an upstream disruption happens.
If you add automation hardware faster than your WES can support, you build up technical debt you don't see until volume stresses the system. Every new piece of automation, whether it's an AS/RS, an AMR fleet, or another robotic pick station, adds combinatorial complexity the WES has to resolve, and a WES that wasn't built for mixed-fleet environments produces inconsistent API quality that turns into sequencing errors on the floor. The strategic value of the entire control stack lives in coordination: a conveyor system and a robot arm can both be excellent pieces of equipment and still underperform badly if the layer coordinating their timing wasn't designed for the complexity the facility has grown into.
End-of-arm tooling and conveyor interface co-design for mixed-SKU environments
A gripper designed without reference to how the conveyor presents product will fail at the pick station even if it's an excellent gripper in isolation. End-of-arm tooling and conveyor geometry have to be designed together. A robot is only as effective as the tooling on the end of its arm, and choosing the wrong interface leads to dropped product, damaged packaging, or stacks that won't hold stable; the same problem that shows up at palletizing cells also occurs at the pick station itself.
Most facilities don't run a single product line forever, and tool-changing hardware now lets a robot swap its gripper in as little as five seconds with no manual screwing or wrench work, moving between heavy items and fragile cartons without a person stepping in. That speed only pays off if the conveyor's presentation geometry and speed profile are matched to each tooling configuration in use, because a fast tool change means nothing if the belt is still feeding product at the wrong height or spacing for whichever gripper just got mounted. For mixed-SKU parcel operations, AI-driven gripping removes the need to pre-program gripper behavior for every SKU that might show up. The combination of CMES Robotics' AI Vision and Engineering Innovation's Chameleon® Parcel Sorting System, announced as a joint solution at MODEX 2026, targets exactly this bottleneck: breaking down gaylords full of mixed parcels and feeding them onto conveyors has historically been manual work, and AI Vision lets the system pick regardless of shape, size, or packaging without programming each parcel type in advance.
The conveyor's share of this co-design is to make sure product arrives at the pick point correctly spaced, at a consistent height, and within the robot's reach. A high-speed pick-and-place system built around a SCARA robot with integrated camera-based conveyor tracking reached up to 120 parts per minute, but that number only holds if you treat conveyor width, product stops, and lane guides as design variables from the start, not settle them after installation. Piece picking, pulling individual items out of a bin with irregular shapes, mixed SKUs, and inconsistent orientation, remains the hardest version of this problem to automate fully. For most operations today, a hybrid model, robotic picking for bulk volume and human picking for exceptions, is still the practical standard. You need to build the conveyor-robot interface so it hands those exceptions off gracefully to a person instead of faulting the whole line when a robot can't confidently make the pick.
Digital twins and pre-commissioning simulation as risk reduction for integration projects
Every junction described above, the PLC handshake, the accumulation buffer sizing, the vision latency budget, the WES sequencing logic, can be modeled and stress-tested before any of it is bolted to the floor. A digital twin of the conveyor-robot system lets engineers simulate product arrival rates, slug conditions, and sortation timing against the actual cycle time of the robot and tooling planned for each station, surfacing undersized buffers or mismatched sortation rates as a parameter to adjust in simulation before commissioning begins. Running the handshake logic itself against simulated fault conditions, an interlock trip at the wrong moment, a vision system returning a low-confidence read, a conveyor fault mid-cycle, exposes gaps in the state logic before a tripped light curtain becomes a six-figure downtime event on a live floor. So much of conveyor-robot integration failure traces back to the junctions between layers rather than the layers themselves, and if you simulate those junctions ahead of installation, you can catch a mismatch between sortation speed and pick-station capacity, or between WES sequencing assumptions and actual buffer behavior, while it still costs nothing more than engineering time to fix.
Sources
- Robotic Pick and Place Conveyor Solution
- Robotic order picking system
- "PLC Multi-robot Integration via Ethernet for Human Operated Quality Sa" by Jeevan S. Devagiri, Paniz Khanmohammadi Hazaveh et al.
- Integration Of Robotic Arm And Conveyor With Programmable Logic Controller
- Picking a Conveyor Clean by an Autonomously Learning Robot
- Accumulating shuttle conveyor
- Visual conveyor tracking for "pick-on-the-fly" robot motion control
- (PDF) Conveyor visual tracking using robot vision